Multiple Degrees of Freedom Systems and Mode Shapes
The simple mass–spring damper model is the foundation of vibration analysis, but what about more complex systems? The mass–spring–damper model described above is called a single degree of freedom (SDOF) model since we have assumed the mass only moves up and down. In the case of more complex systems we need to discretize the system into more masses and allow them to move in more than one direction – adding degrees of freedom. The major concepts of multiple degrees of freedom (MDOF) can be understood by looking at just a 2 degree of freedom model as shown in the figure.
The equations of motion of the 2DOF system are found to be:
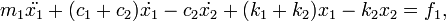

We can rewrite this in matrix format:

A more compact form of this matrix equation can be written as:

where and are symmetric matrices referred respectively as the mass, damping, and stiffness matrices. The matrices are NxN square matrices where N is the number of degrees of freedom of the system.
In the following analysis we will consider the case where there is no damping and no applied forces (i.e. free vibration). The solution of a viscously damped system is somewhat more complicated.
This differential equation can be solved by assuming the following type of solution:

Note: Using the exponential solution of is a mathematical trick used to solve linear differential equations. If we use Euler's formula and take only the real part of the solution it is the same cosine solution for the 1 DOF system. The exponential solution is only used because it easier to manipulate mathematically.
The equation then becomes:
Since cannot equal zero the equation reduces to the following.
Read more about this topic: Vibration
Famous quotes containing the words multiple, degrees, freedom, systems, mode and/or shapes:
“Creativity seems to emerge from multiple experiences, coupled with a well-supported development of personal resources, including a sense of freedom to venture beyond the known.”
—Loris Malaguzzi (20th century)
“I was by degrees awakened as from a dream, and feared that my whole life could properly be counted nothing else but a fantastic vision.”
—Sarah Fielding (1710–1768)
“If we don’t believe in freedom of expression for people we despise, we don’t believe in it at all.”
—Noam Chomsky (b. 1928)
“What is most original in a man’s nature is often that which is most desperate. Thus new systems are forced on the world by men who simply cannot bear the pain of living with what is. Creators care nothing for their systems except that they be unique. If Hitler had been born in Nazi Germany he wouldn’t have been content to enjoy the atmosphere.”
—Leonard Cohen (b. 1934)
“Almost any mode of observation will be successful at last, for what is most wanted is method.”
—Henry David Thoreau (1817–1862)
“Some say that gleams of a remoter world
Visit the soul in sleep,—that death is slumber,
And that its shapes the busy thoughts outnumber
Of those who wake and live.—”
—Percy Bysshe Shelley (1792–1822)