Twists As Elements of A Lie Algebra
Consider the movement of a rigid body defined by the parameterized 4x4 homogeneous transform,
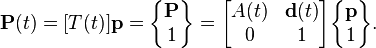
This notation does not distinguish between P = (X, Y, Z, 1), and P = (X, Y, Z), which is hopefully clear in context.
The velocity of this movement is defined by computing the velocity of the trajectories of the points in the body,

The dot denotes the derivative with respect to time, and because p is constant its derivative is zero.
Substitute the inverse transform for p into the velocity equation to obtain the velocity of P by operating on its trajectory P(t), that is
where
Recall that is the angular velocity matrix. The matrix is an element of the Lie algebra se(3) of the Lie group SE(3) of homogeneous transforms. The components of are the components of the twist screw, and for this reason is also often called a twist.
From the definition of the matrix, we can formulate the ordinary differential equation,
and ask for the movement that has a constant twist matrix . The solution is the matrix exponential
This formulation can be generalized such that given an initial configuration g(0) in SE(n), and a twist ξ in se(n), the homogeneous transformation to a new location and orientation can be computed with the formula,
where θ represents the parameters of the transformation.
Read more about this topic: Screw Theory
Famous quotes containing the words elements, lie and/or algebra:
“In verse one can take any damn constant one likes, one can alliterate, or assone, or rhyme, or quant, or smack, only one MUST leave the other elements irregular.”
—Ezra Pound (1885–1972)
“Through throats where many rivers meet, the curlews cry,
Under the conceiving moon, on the high chalk hill,
And there this night I walk in the white giant’s thigh
Where barrren as boulders women lie longing still
To labour and love though they lay down long ago.”
—Dylan Thomas (1914–1953)
“Poetry has become the higher algebra of metaphors.”
—José Ortega Y Gasset (1883–1955)